3.7. RAS-Server for EC-Lyser and EC-Engineer
3.7.1. Integration Requirements
To use the diagnosis tool EC-Lyser with a customer application, some modifications have to be done during integration of the EC-Simulator. The task is to integrate and start the Remote API Server system within the custom application, which provides a socket based uplink, which later on is connected by the EC-Lyser.
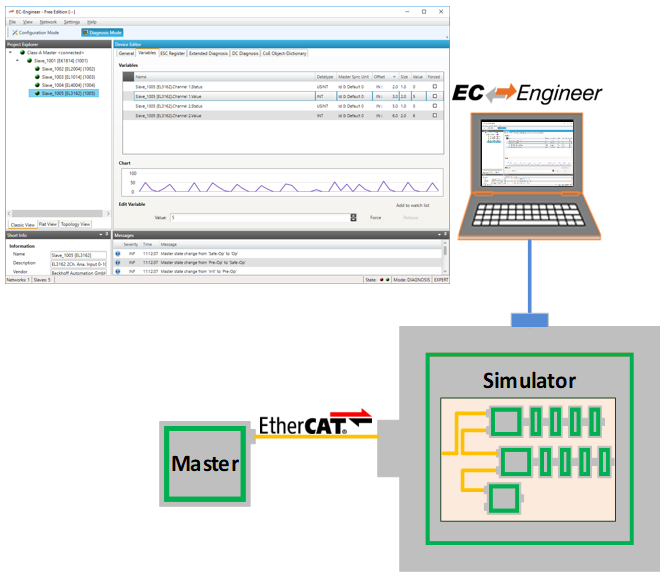
An example on how to integrate the Remote API Server within the application is given with the example application EcSimulatorHilDemo, which is preconfigured to listen for EC-Lyser on TCP Port 6000 when command line parameter “-sp” is given.
To demonstrate the steps needed within a custom application, a developer may use the following pseudo-code segment as a point of start. The Remote API Server library “EcSimulatorRasServer” must be linked.
3.7.2. Pseudo Code
#include "EcSimulatorRasServer.h"

/* custom Remote API Notification handler, example in EcSimulatorHilDemo (EcNotification.cpp) */
EC_T_DWORD RasNotifyCallback(
    EC_T_DWORD          dwCode,     /**< [in]   Notification code identifier */
    EC_T_NOTIFYPARMS*   pParms      /**< [in]   Notification data portion */
                    )
{
    /* custom notification handler */
}
    /* initialization  */
    EC_T_RAS_SERVER_PARMS  oRemoteApiConfig;
    OsMemset(&oRemoteApiConfig, 0, sizeof(EC_T_RAS_SERVER_PARMS));
    EC_T_PVOID          pvRemApiHandle;
    oRemoteApiConfig.dwSignature            = EC_RAS_SERVER_SIGNATURE;
    oRemoteApiConfig.dwSize                 = sizeof(EC_T_RAS_SERVER_PARMS);
    /* INADDR_ANY */
    oRemoteApiConfig.oAddr.dwAddr           = 0;
    /*< default is port 6000 > */
    oRemoteApiConfig.wPort                  = wServerPort;
    /*< default is 2 ms */
    oRemoteApiConfig.dwCycleTime            = EC_RAS_CYCLE_TIME;
    oRemoteApiConfig.dwCommunicationTimeout = EC_RAS_MAX_WATCHDOG_TIMEOUT;
    EC_CPUSET_ZERO(oRemoteApiConfig.oAcceptorThreadCpuAffinityMask);
    oRemoteApiConfig.dwAcceptorThreadPrio           = MAIN_THREAD_PRIO;
    oRemoteApiConfig.dwAcceptorThreadStackSize      = JOBS_THREAD_STACKSIZE;
    EC_CPUSET_ZERO(oRemoteApiConfig.oClientWorkerThreadCpuAffinityMask);
    oRemoteApiConfig.dwClientWorkerThreadPrio       = MAIN_THREAD_PRIO;
    oRemoteApiConfig.dwClientWorkerThreadStackSize  = JOBS_THREAD_STACKSIZE;
    /* RAS notification callback function */
    oRemoteApiConfig.pfnRasNotify     = RasNotifyCallback;
    /* RAS notification callback function context */
    oRemoteApiConfig.pvRasNotifyCtxt = pAppContext->pNotificationHandler;
    /* pre-allocation */
    oRemoteApiConfig.dwMaxQueuedNotificationCnt = 100;
    /* pre-allocation */
    oRemoteApiConfig.dwMaxParallelMbxTferCnt       = 50;
    /* span between to consecutive cyclic notifications of same type */
    oRemoteApiConfig.dwCycErrInterval              = 500;

    /* init simulator */
    esInitSimulator(...);

    /* start remote API server */
    esRasSrvStart(dwSimulatorInstanceId, &oRemoteApiConfig, &pvRemApiHandle);

    /* stop remote API server */
    esRasSrvStop(dwSimulatorInstanceId, pvRemApiHandle, 2000)

    esDeinitSimulator(...);
}
3.7.3. Required API Calls
3.7.3.1. esRasSrvStart
-
EC_T_DWORD EC_NAMESPACE::esRasSrvStart(const EC_T_RAS_SERVER_PARMS *pParms, EC_T_PVOID *ppHandle)
Starts the RAS Server.
- Parameters:
pParms – [in] Server start-up parameters
ppHandle – [out] Handle to opened instance, used for ctrl access
- Returns:
EC_E_NOERROR or error code
-
struct EC_T_RAS_SERVER_PARMS
Public Members
-
EC_T_DWORD dwSignature
[in] Set to EC_RAS_SERVER_SIGNATURE
-
EC_T_DWORD dwSize
[in] Set to sizeof(EC_T_RAS_SERVER_PARMS)
-
EC_T_LOG_PARMS LogParms
[in] Logging parameters
-
EC_T_IPADDR oAddr
[in] Remote Access Server (RAS) listen IP address
-
EC_T_WORD wPort
[in] Remote Access Server (RAS) listen port
-
EC_T_WORD wMaxClientCnt
[in] Max. clients in parallel (0: unlimited)
-
EC_T_DWORD dwCycleTime
[in] Cycle Time of RAS Network access (acceptor, worker)
-
EC_T_DWORD dwCommunicationTimeout
[in] Timeout [ms] before automatically closing connection
-
EC_T_DWORD dwAcceptorThreadPrio
[in] Acceptor Thread Priority
-
EC_T_DWORD dwAcceptorThreadStackSize
[in] Acceptor Thread Stack Size
-
EC_T_DWORD dwClientWorkerThreadPrio
[in] Client Worker Thread Priority
-
EC_T_DWORD dwClientWorkerThreadStackSize
[in] Client Worker Thread Stack Size
-
EC_T_DWORD dwMaxQueuedNotificationCnt
[in] Amount of concurrently queue able Notifications
-
EC_T_DWORD dwMaxParallelMbxTferCnt
[in] Amount of concurrent active mailbox transfers
-
EC_PF_NOTIFY pfnRasNotify
[in] Function pointer called to notify error and status information generated by Remote API Layer
-
EC_T_DWORD dwCycErrInterval
[in] Interval which allows cyclic Notifications
-
EC_T_DWORD dwMaxQueuedNotificationSize
[in] Size of concurrent active mailbox transfers
-
EC_T_BYTE *pbyTlsCert
[in] TLS certificate filename string
-
EC_T_DWORD dwTlsCertSize
[in] Size of TLS certeficate
-
EC_T_BYTE *pbyTlsPrivKey
[in] TLS private key filename string
-
EC_T_DWORD dwTlsPrivKeySize
[in] Size of TLS private key
-
EC_T_DWORD dwSignature
-
union EC_T_IPADDR
- #include <EthernetServices.h>
Public Members
-
EC_T_INNER_IPADDR sAddr
IPv4 address (endianness independent)
-
EC_T_DWORD dwAddr
Reserved, use EC_T_IPADDR::sAddr.by instead. OS-Layer socket API calls (SOCKADDR_IN::sin_addr).
-
EC_T_INNER_IPADDR sAddr
-
struct EC_T_INNER_IPADDR
Public Members
-
EC_T_BYTE by[4]
IPv4 address (endianness independent)
-
EC_T_BYTE by[4]
3.7.3.2. esRasSrvStop
-
EC_T_DWORD EC_NAMESPACE::esRasSrvStop(EC_T_PVOID pvHandle, EC_T_DWORD dwTimeout)
Stops the RAS Server.
- Parameters:
pvHandle – [in] Handle to previously started Server
dwTimeout – [in] Timeout [ms] used to shut down all spawned threads, it’s multiplied internally by the amount of threads spawned
- Returns:
EC_E_NOERROR or error code
3.7.3.3. RasNotifyCallback - xxx
Callback function called by Remote API Server in case of State changes or error situations.
Data structure filled with detailed information about the according notification.
-
struct EC_T_NOTIFYPARMS
3.7.3.4. RasNotifyCallback - EC_RAS_NOTIFY_CONNECTION
Notification about a change in the Remote API’s state.
- RasNotifyCallback - EC_RAS_NOTIFY_CONNECTION
- Parameter
pbyInBuf: [in] Pointer to data of type EC_T_RAS_CONNOTIFYDESCdwInBufSize: [in] Size of the input buffer in bytespbyOutBuf: [out] Should be set to EC_NULLdwOutBufSize: [in] Should be set to 0pdwNumOutData: [out] Should be set to EC_NULL
Data structure containing the new Remote API state and the cause of state change.
-
struct EC_T_RAS_CONNOTIFYDESC
Public Members
-
EC_T_DWORD dwCause
[in] Cause of state connection state change
-
EC_T_DWORD dwCookie
[in] Unique identification cookie of connection instance
-
EC_T_DWORD dwCause
3.7.3.5. RasNotifyCallback - EC_RAS_NOTIFY_REGISTER
Notification that a connected application registered a client to the stack.
- RasNotifyCallback - EC_RAS_NOTIFY_REGISTER
- Parameter
pbyInBuf: [in] Pointer to data of type EC_T_RAS_REGNOTIFYDESCdwInBufSize: [in] Size of the input buffer in bytespbyOutBuf: [out] Should be set to EC_NULLdwOutBufSize: [in] Should be set to 0pdwNumOutData: [out] Should be set to EC_NULL
-
struct EC_T_RAS_REGNOTIFYDESC
Public Members
-
EC_T_DWORD dwCookie
[in] Unique identification cookie of connection instance
-
EC_T_DWORD dwResult
[in] Result of registration request
-
EC_T_DWORD dwInstanceId
[in] Master Instance client registered to
-
EC_T_DWORD dwClientId
[in] Client ID of registered client
-
EC_T_DWORD dwCookie
3.7.3.6. RasNotifyCallback - EC_RAS_NOTIFY_UNREGISTER
Notification that a connected application un-registered a client from the simulator stack.
- RasNotifyCallback - EC_RAS_NOTIFY_UNREGISTER
- Parameter
pbyInBuf: [in] Pointer to data of type EC_T_RAS_REGNOTIFYDESCdwInBufSize: [in] Size of the input buffer in bytespbyOutBuf: [out] Should be set to EC_NULLdwOutBufSize: [in] Should be set to 0pdwNumOutData: [out] Should be set to EC_NULL
3.7.3.7. RasNotifyCallback - EC_RAS_NOTIFY_MARSHALERROR
Notification about an error during marshalling in Remote API Server connection layer.
- RasNotifyCallback - EC_RAS_NOTIFY_MARSHALERROR
- Parameter
pbyInBuf: [in] Pointer to data of type EC_T_RAS_MARSHALERRORDESCdwInBufSize: [in] Size of the input buffer in bytespbyOutBuf: [out] Should be set to EC_NULLdwOutBufSize: [in] Should be set to 0pdwNumOutData: [out] Should be set to EC_NULL
-
struct EC_T_RAS_MARSHALERRORDESC
Public Members
-
EC_T_DWORD dwCookie
[in] Unique identification cookie of connection instance
-
EC_T_DWORD dwCause
[in] Cause of the command marshalling error
-
EC_T_DWORD dwLenStatCmd
[in] Length of the faulty command
-
EC_T_DWORD dwCommandCode
[in] Command code of the faulty command
-
EC_T_DWORD dwCookie
3.7.3.8. RasNotifyCallback - EC_RAS_NOTIFY_ACKERROR
Notification about an error during creation of ack / nack packet.
- RasNotifyCallback - EC_RAS_NOTIFY_ACKERROR
- Parameter
pbyInBuf: [in] Pointer to EC_T_DWORD containing error codedwInBufSize: [in] Size of the input buffer in bytespbyOutBuf: [out] Should be set to EC_NULLdwOutBufSize: [in] Should be set to 0pdwNumOutData: [out] Should be set to EC_NULL
3.7.3.9. RasNotifyCallback - EC_RAS_NOTIFY_NONOTIFYMEMORY
Notification given, when no empty buffers for notifications are available in pre-alloced notification store. This points to a configuration error.
- RasNotifyCallback - EC_RAS_NOTIFY_NONOTIFYMEMORY
- Parameter
pbyInBuf: [in] Pointer to EC_T_DWORD containing a unique identification cookie of connection instancedwInBufSize: [in] Size of the input buffer in bytespbyOutBuf: [out] Should be set to EC_NULLdwOutBufSize: [in] Should be set to 0pdwNumOutData: [out] Should be set to EC_NULL
3.7.3.10. RasNotifyCallback - EC_RAS_NOTIFY_STDNOTIFYMEMORYSMALL
Notification given when the buffer size for standard notifications available in pre-alloced notification store is too small to carry a specific notification. This points to a configuration error.
3.7.3.11. RasNotifyCallback - EC_RAS_NOTIFY_MBXNOTIFYMEMORYSMALL
Notification given when the buffer size for Mailbox notifications available in pre-alloced notification store is too small to carry a specific notification. This points to a configuration error.
- RasNotifyCallback - EC_RAS_NOTIFY_MBXNOTIFYMEMORYSMALL
- Parameter
pbyInBuf: [in] Pointer to EC_T_DWORD containing unique identification cookie of connection instancedwInBufSize: [in] Size of the input buffer in bytespbyOutBuf: [out] Should be set to EC_NULLdwOutBufSize: [in] Should be set to 0pdwNumOutData: [out] Should be set to EC_NULL
This is a serious error. If this error occurs, Mailbox Transfer objects may have gotten out of sync and are therefore no longer valid.
See also
esRasSrvStart() for Mailbox notifications should be dimensioned correctly.